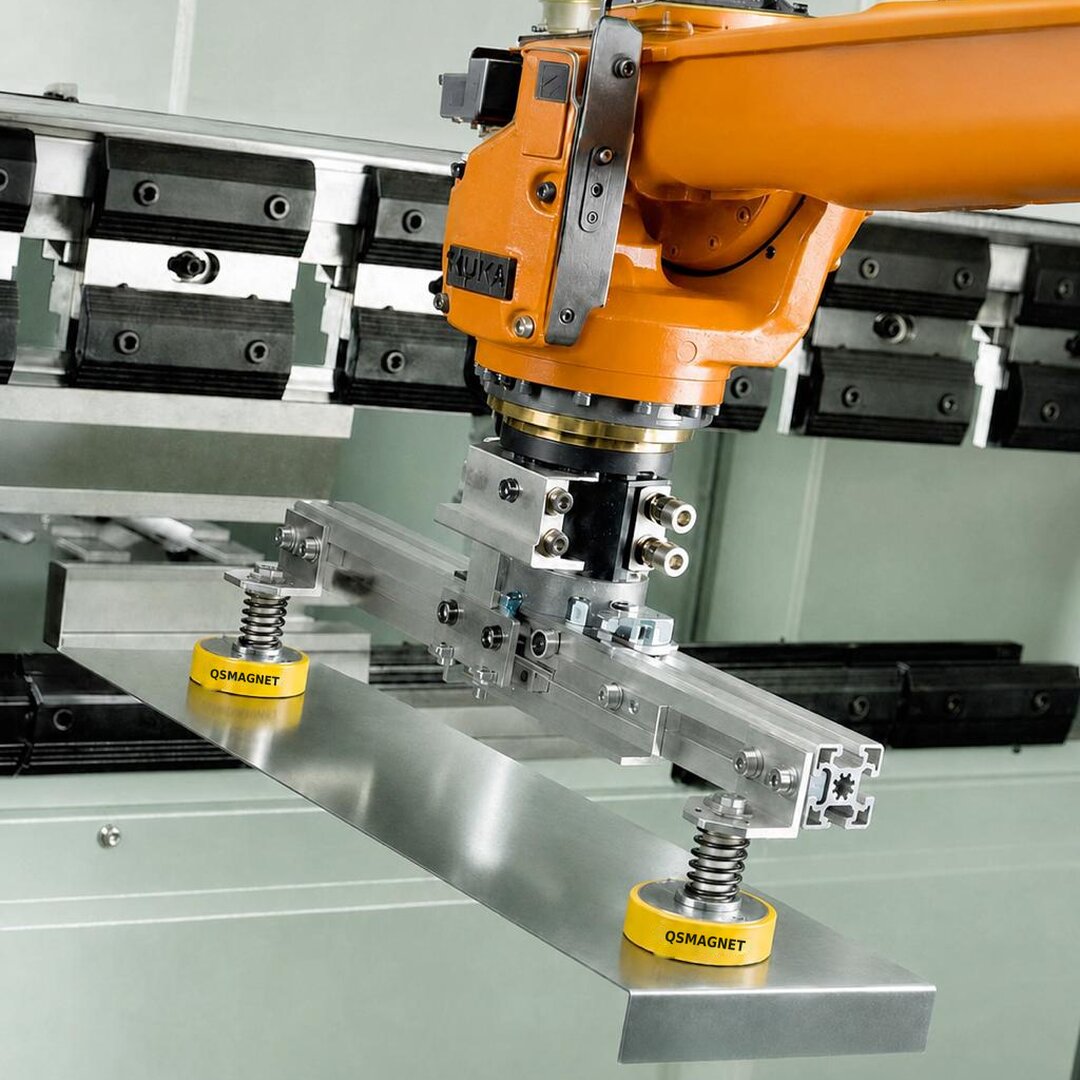
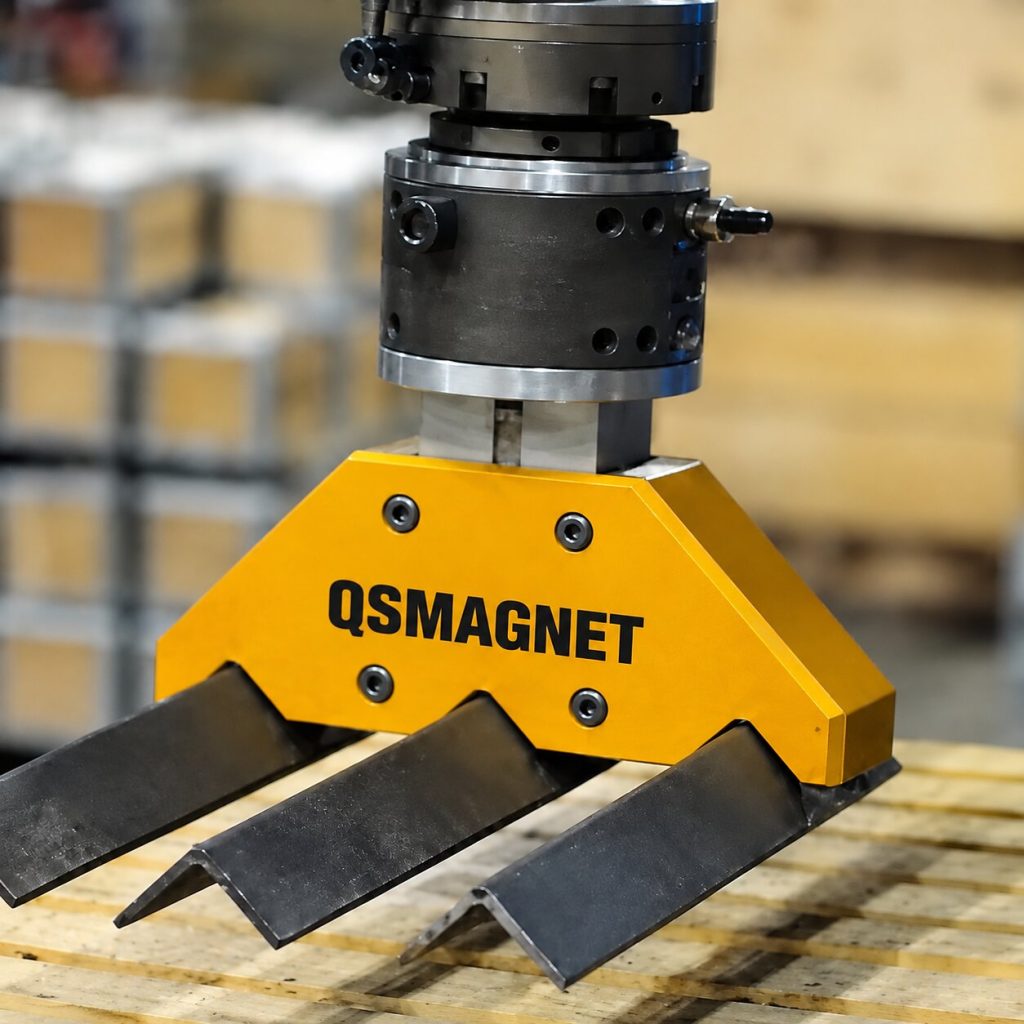
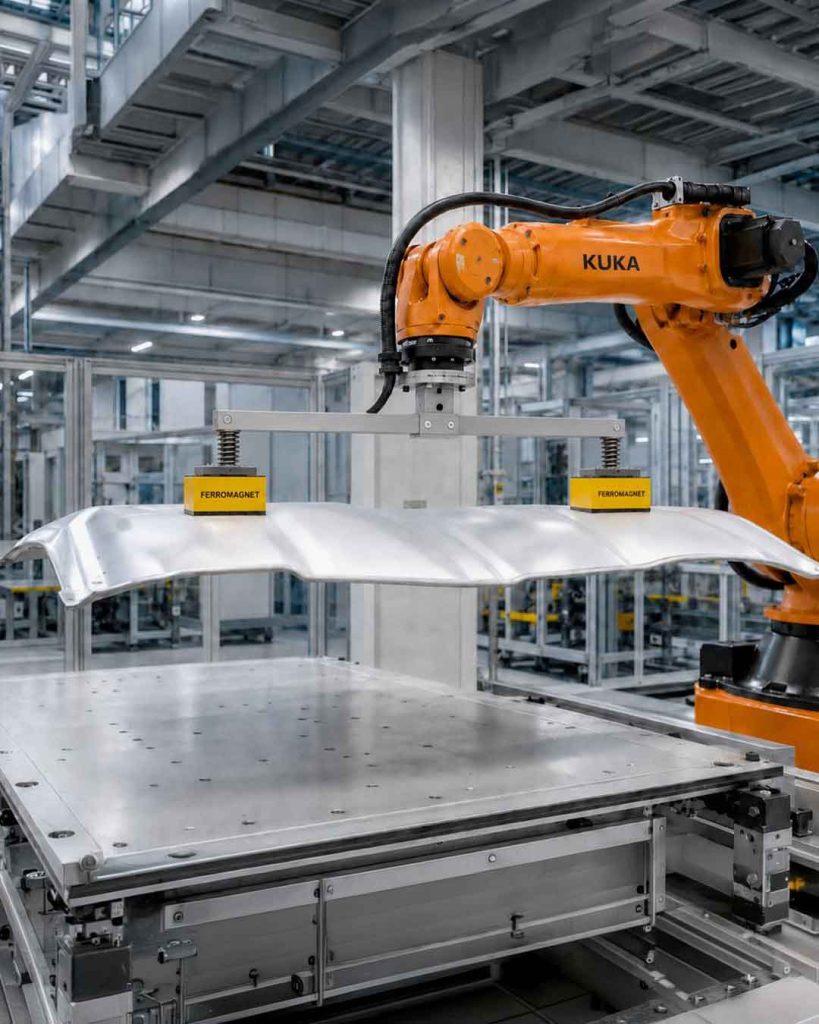
Magnetic gripping solutions for robot end effectors. Let’s assess part properties, mounting interface, robot payload and control requirements together.
With thin and perforated sheets, the usable contact area and the flexing of the part are decisive. Suitability is assessed from the part drawing and, where needed, a trial.