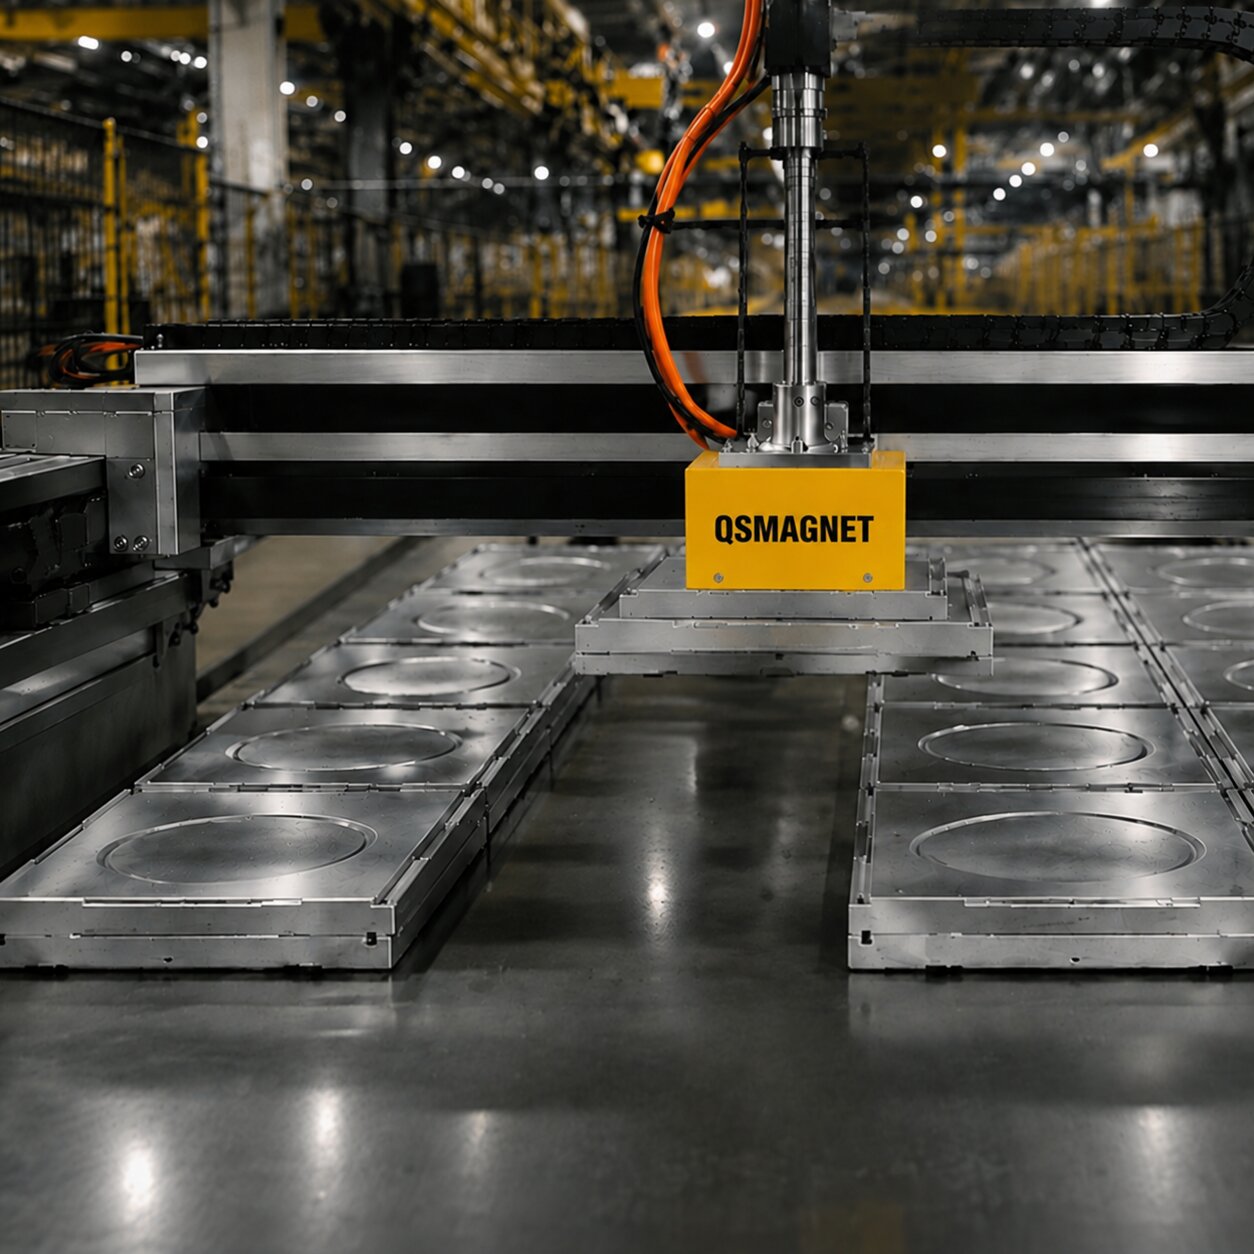
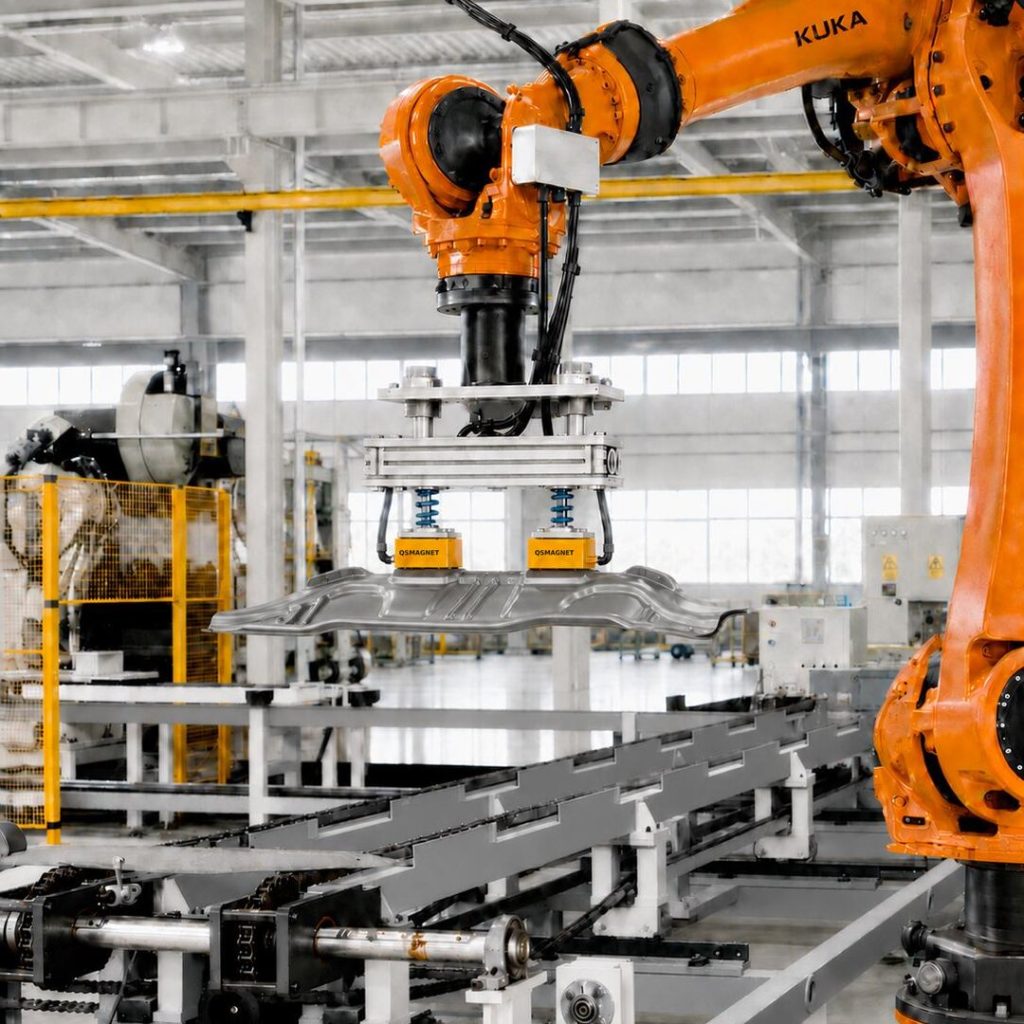
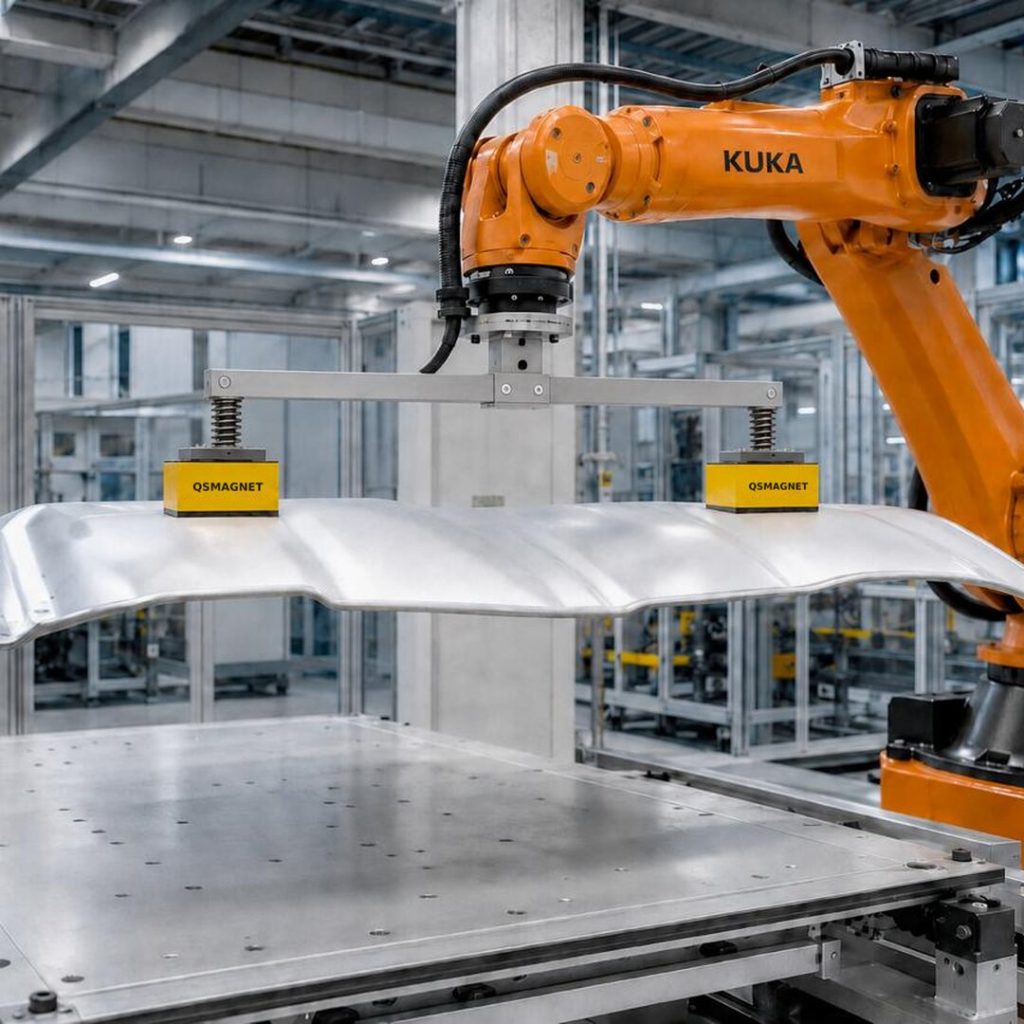
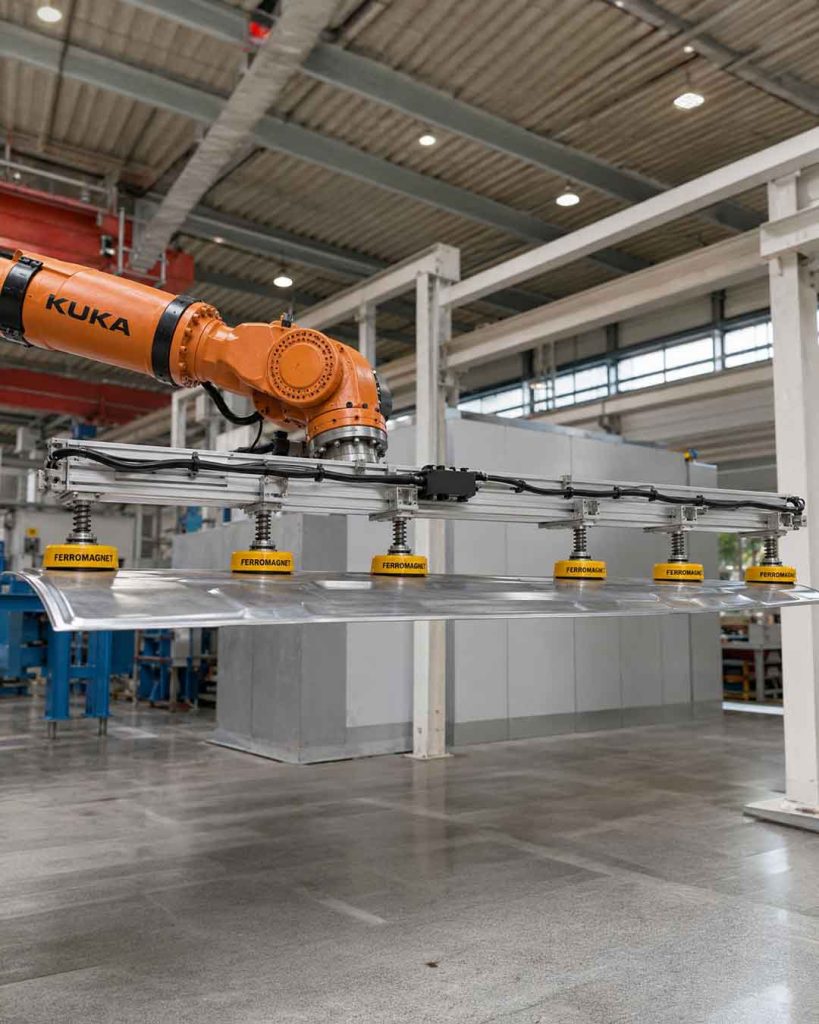
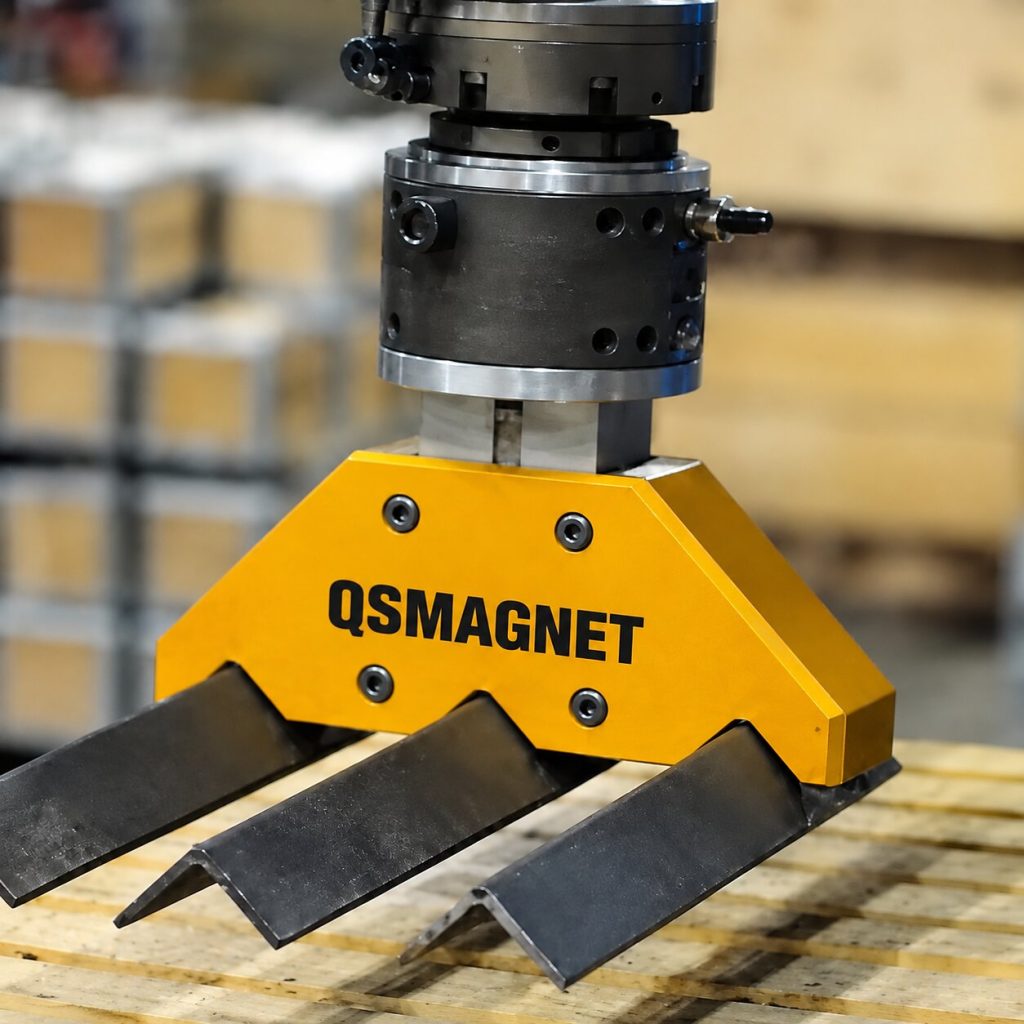
Gripper solutions for robotic picking, transfer and placement of sheet and steel parts suitable for magnetic holding. Let’s assess your part, your robot and your working method together.
Part properties, robot model, total payload including the gripper, and motion conditions are reviewed together. Mounting and control connections are assessed for each application.
With thin and perforated sheets, the usable contact area, part flexing and thickness are decisive. Suitability is assessed from the part drawing and, where needed, a trial.
Robot model and flange details, part drawing and weight, pick-and-place points, target cycle time and the control signals to be used are required for the assessment.
Tell us about your part and your process.
Start with a photo or drawing of the part. Add your robot model, if you have one, and the operation you have in mind.