Robotic Grippers
How Is Perforated Sheet Handled with a Robot? Choosing a Vacuum or Magnetic Gripper
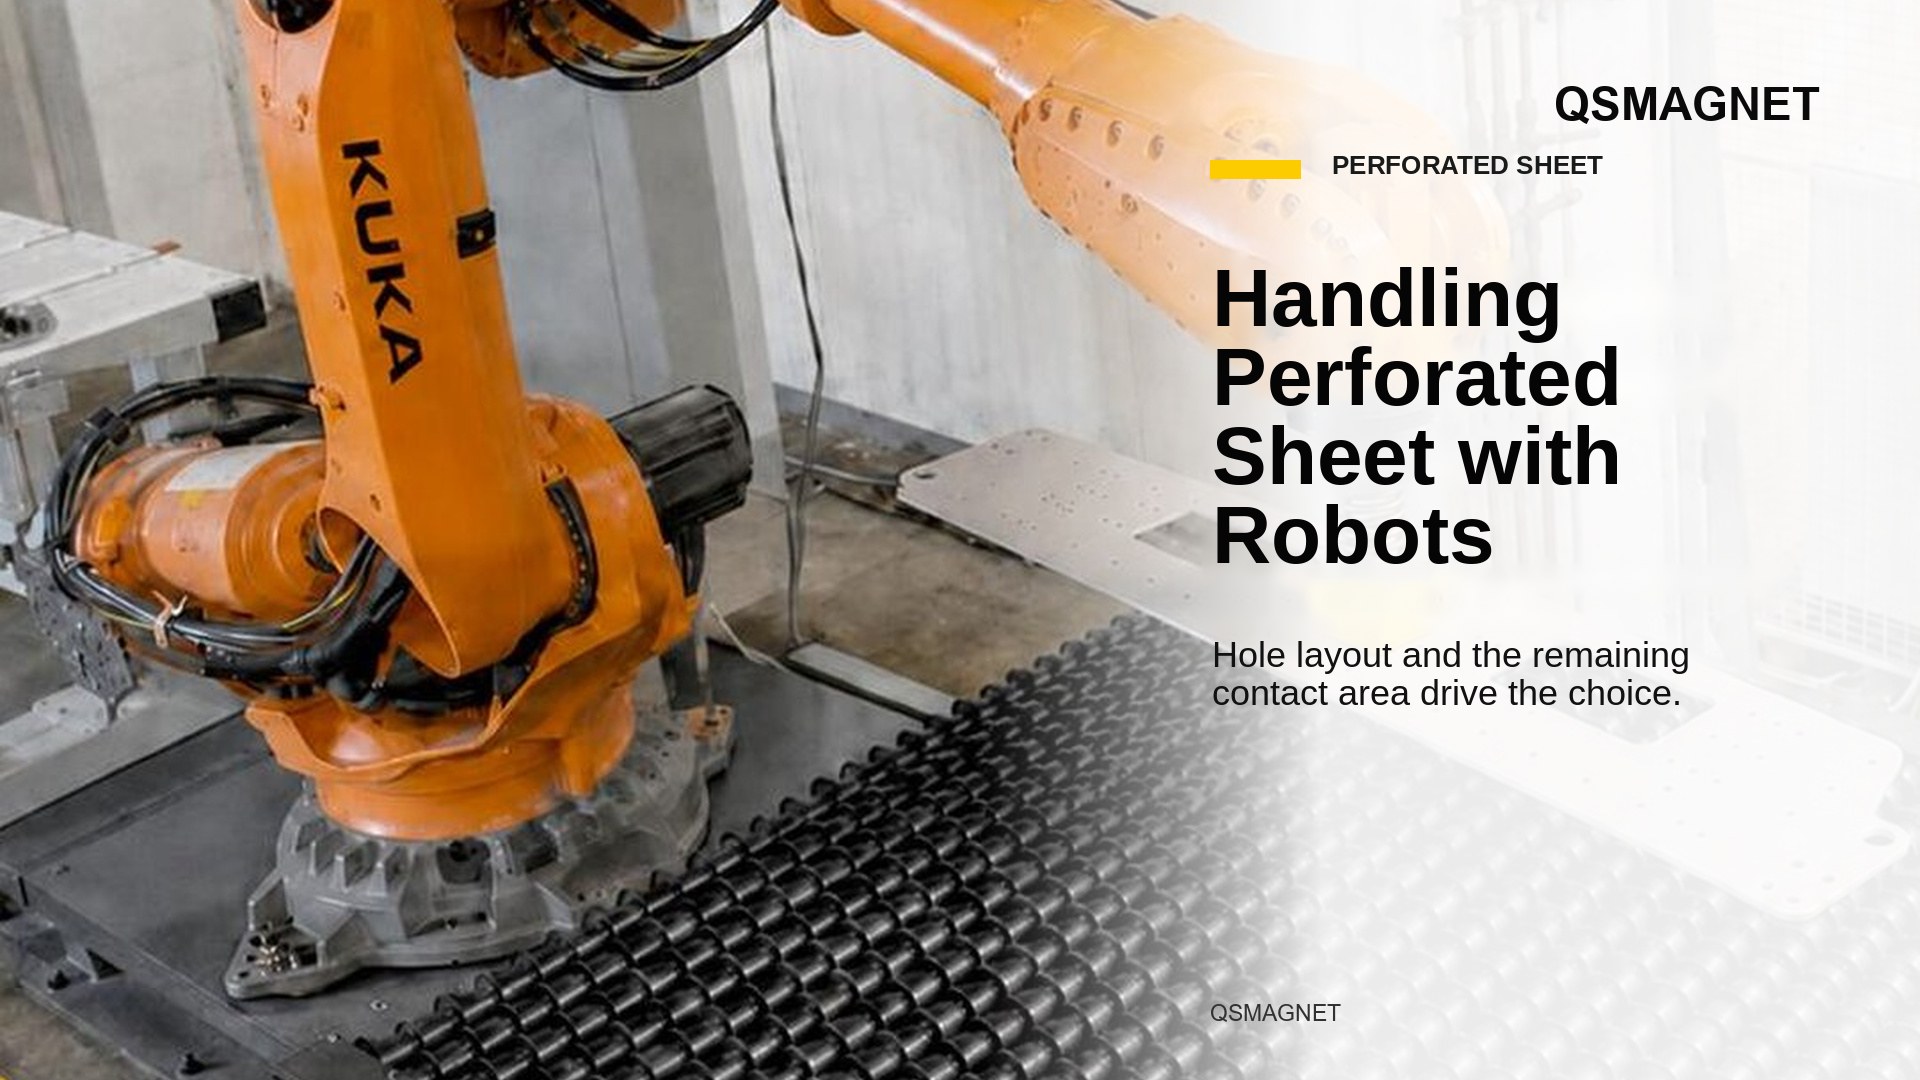
For perforated sheet, gripper selection depends on the hole layout and the surface left for holding. For steel parts suitable for magnetic holding, your application can be assessed using QSMAGNET magnetic gripper solutions for automation. The real contact conditions of the chosen gripper must be verified on your part.
Because the QSMAGNET gripper can be adapted to the part, a magnetic holding layout can be designed to suit the solid areas of the perforated sheet.
Hole layout matters as much as the number of holes
A magnetic gripper needs proper contact between its working face and the part. A narrow bridge, a large opening or holes under the gripper can limit this contact. Being magnetic does not mean the part can be held under the same conditions at every point.
Mark on your part drawing the areas you can set aside for gripping. If two products that look similar have holes in different places, share both drawings. Discuss from the start whether you want the gripper position to change at product changeover.
- Geometry: hole pattern, outer dimensions, bends and solid areas that can be used for gripping.
- Material: steel grade, sheet thickness, surface coating and part weight.
- Motion: the direction in which the robot will move the part and the position needed at release.
Assess vacuum for the application
On the vacuum side, there are gripper designs developed to limit leakage on porous and irregular surfaces. So the suitability of vacuum on a perforated part is assessed on the chosen design and the real surface.
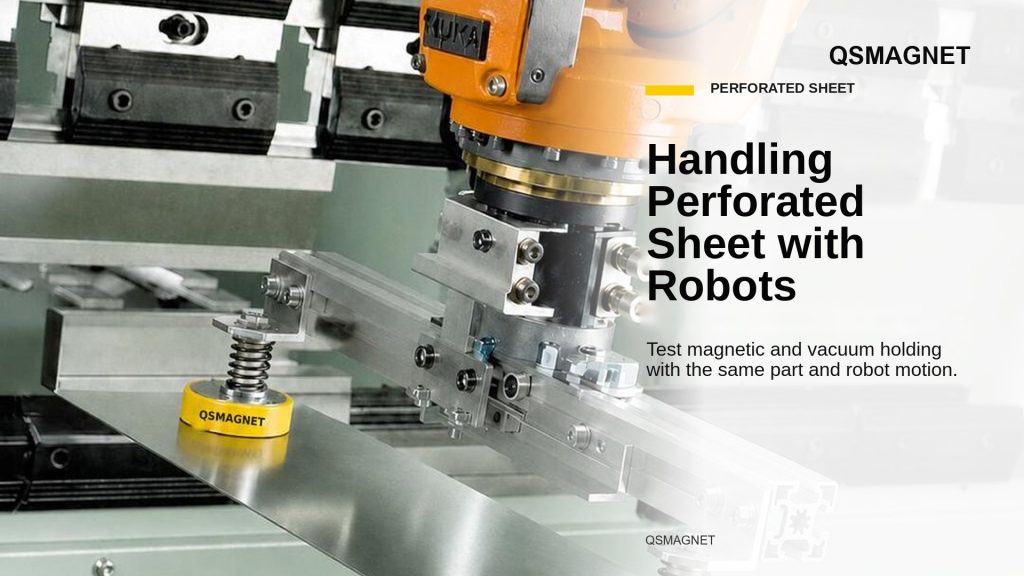
When comparing the two methods, base the comparison on the same part and the same robot motion. In the sample assessment, ask to see the gripping, moving and release results together. Don’t extend a result from one easy part to your whole product list.
Describe the robot’s complete cycle
The gripper’s own weight counts towards the robot calculation; the centre of gravity and dynamic loads are assessed. Also define in the project how part-picked and part-released feedback will be verified. Have the quote scope state clearly which parts will be handled with the same gripper layout.
Frequently asked questions
Can perforated aluminium sheet be held magnetically?
It cannot be lifted with standard magnetic holding; another suitable gripping method is chosen.
Are more magnetic modules always the answer?
Layout and the real contact area must be assessed as well as the number of modules.
Send QSMAGNET a drawing showing the hole pattern and your robot model, and discuss a suitable magnetic gripper layout and application scope for your part.
Related articles
All articles
Robotic Grippers
How to Choose a Magnetic Gripper for a Robot
Choosing a magnetic gripper for a robot? Assess material, total payload, centre of gravity…
Read article
Robotic Grippers
How to Choose a Magnetic Gripper for CNC and Press Feeding Robots
For CNC and press feeding, choose a magnetic gripper together with the part, fixture…
Read article
Robotic Grippers
Which Gripper Should You Choose for Robotic Steel Part Palletizing?
For robotic steel part palletizing, choose the gripper by part shape, payload, pallet pattern…
Read article